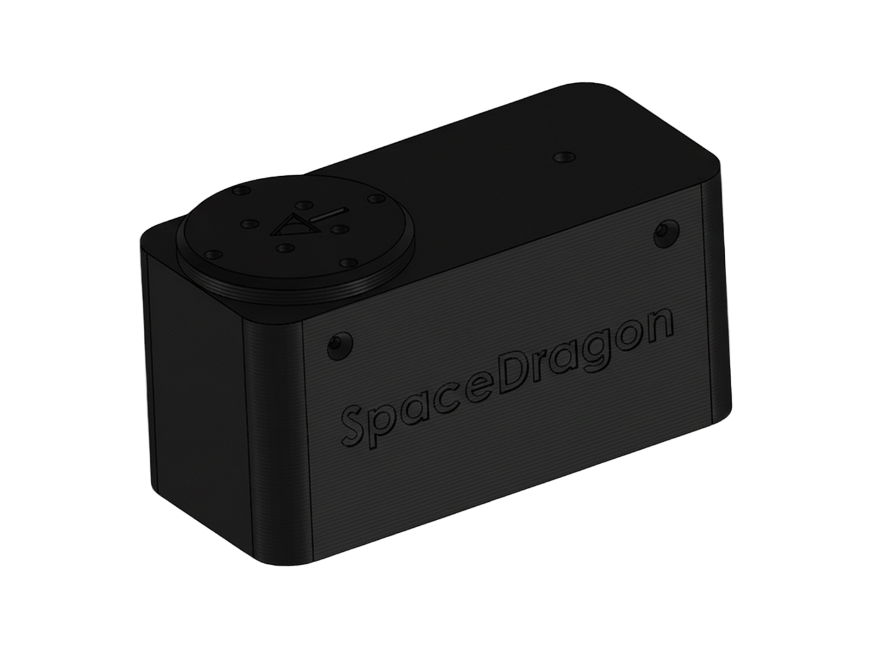
Free on Cults3D2 variants
SA1737 · SA1755
Stepper actuators
Printable NEMA 17 actuators with a 9:1 gearbox, backlash under 1° and an optional AA360 absolute encoder (AS5600 or MT6701) inside. SA1737 for compact joints, SA1755 for 5.5 Nm.
Everything here is free to download, print and build. Each project comes with real documentation: drawings, wiring, specs and the gotchas we found along the way.
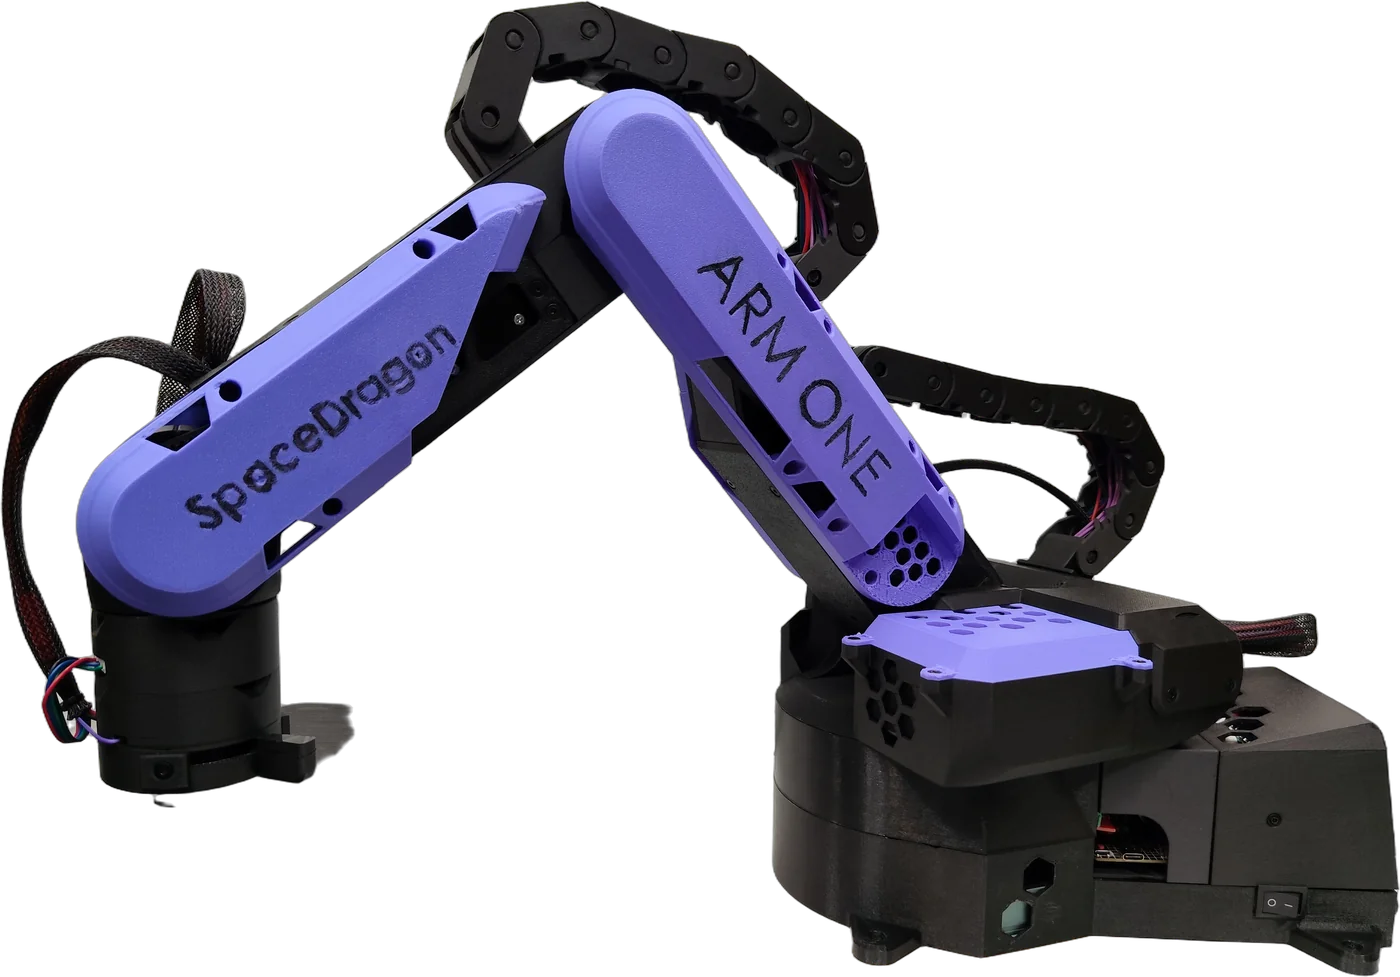
A 3D-printable 5-axis arm built from standard, reusable parts for about €200. Absolute encoders mean no homing, the Dragon-Arm Programmer app writes the code, and Dragon-Claws swaps tools in seconds.
Explore the flagship →
Printable NEMA 17 actuators with a 9:1 gearbox, backlash under 1° and an optional AA360 absolute encoder (AS5600 or MT6701) inside. SA1737 for compact joints, SA1755 for 5.5 Nm.
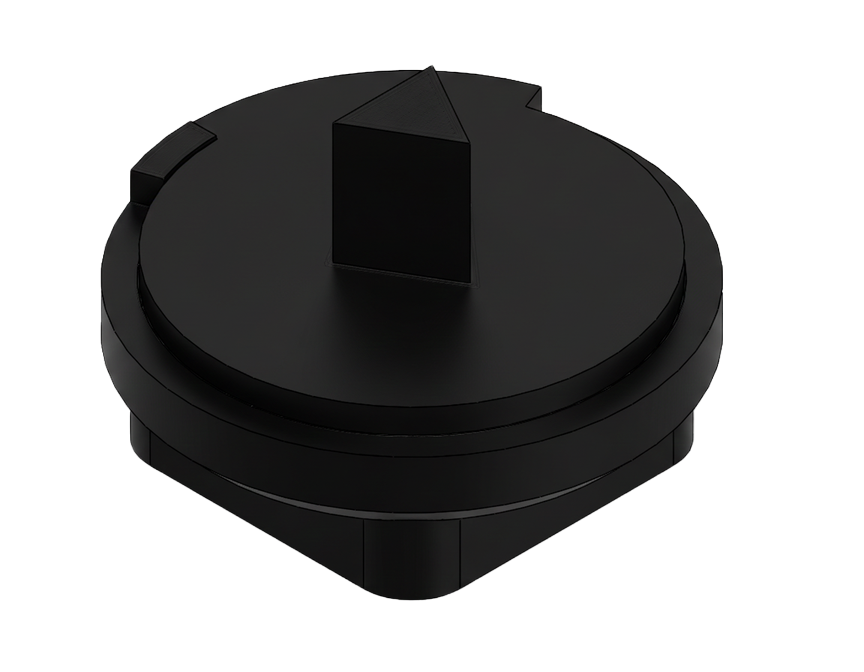
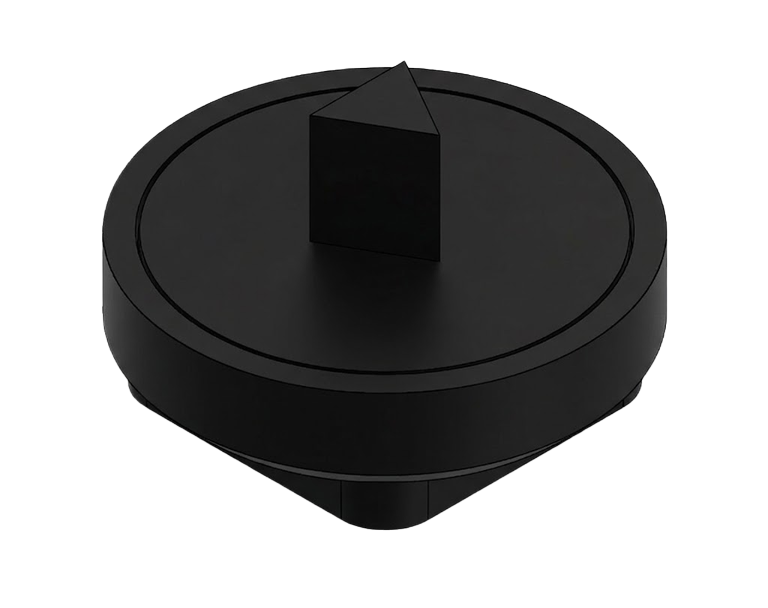
A printable calibrator that turns a cheap AS5600 or MT6701 magnetic encoder board into an AA270 or AA360 absolute angle module: centred magnet, fixed mechanical zero, no re-calibration.
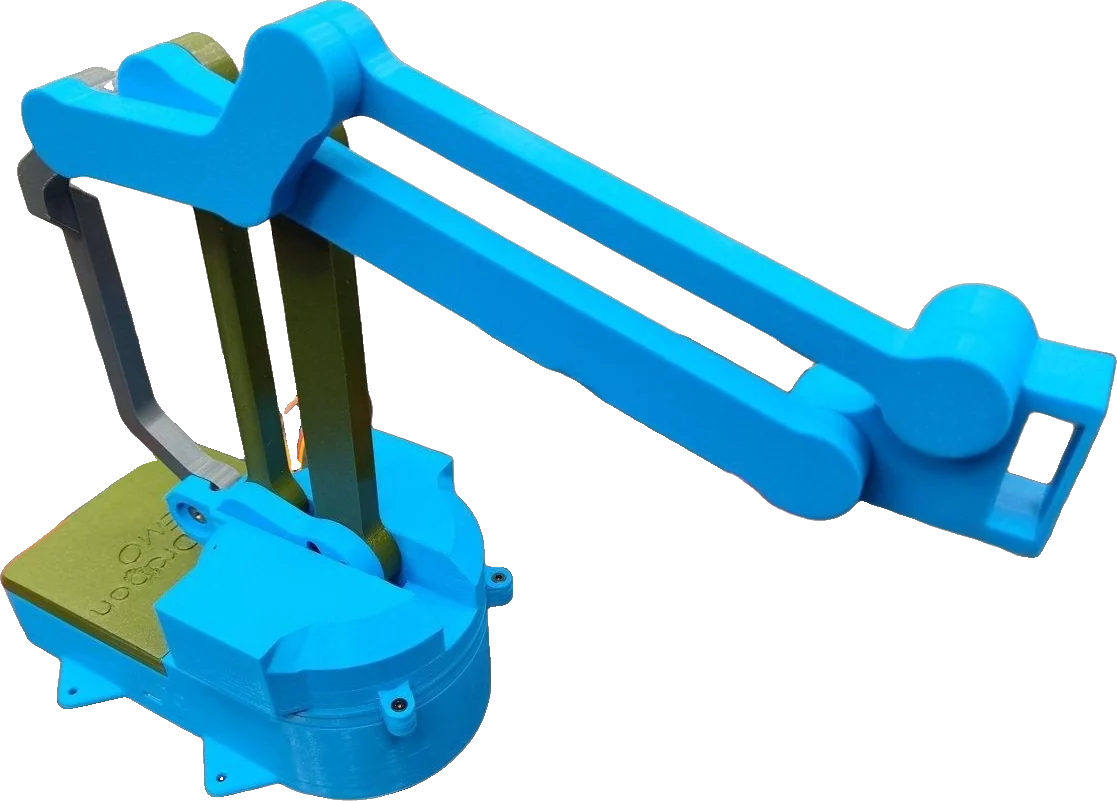
A desktop palletizing arm with a parallel linkage that keeps the tool plate level. Three servos, an Arduino and a PCA9685, programmed visually with the Dragon-Arm Programmer.
Projects in planning. The numbers are design targets, not measured results, and they will change as prototypes get built. Follow along on Discord to see them take shape.
A low-cost drone you can print entirely at home, built for long flights and real payloads.
A new model in the Dragon-Arm family: a 6-axis arm with a 2 kg+ payload, 600 mm+ reach and sub-millimetre accuracy.
A mobile base designed for maximum stability, so it can carry other projects, like a robot arm, over any terrain.
A quadruped aiming for a new level of dynamics in home-built robot dogs.
Illustrations are placeholders, not the final designs.
Follow development, ask questions, share your builds and help shape the next projects.