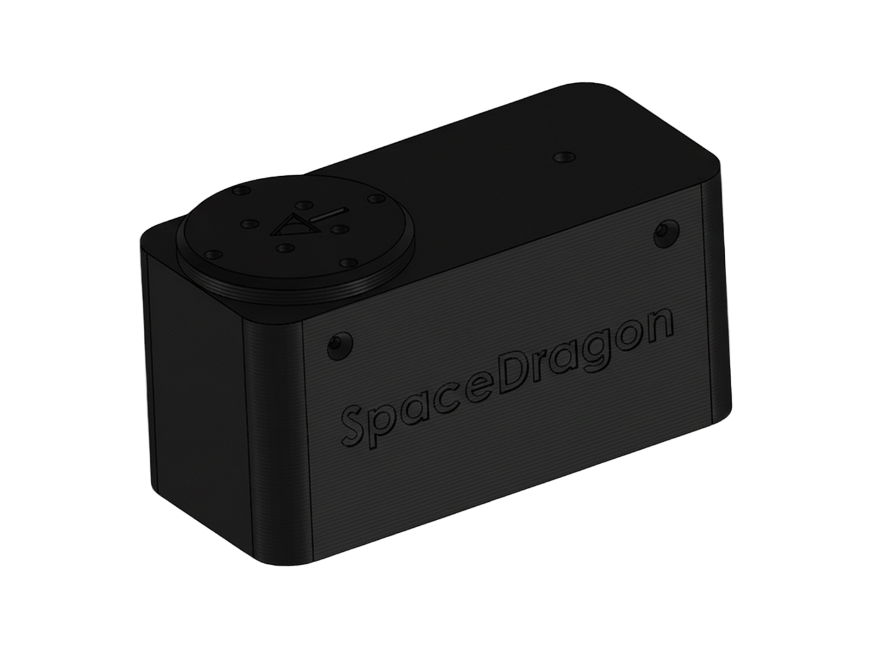
Free on Cults3D2 variants
SA1737 · SA1755
Stepper actuators
Printable NEMA 17 actuators with a 9:1 gearbox, backlash under 1° and an optional AA360 absolute encoder (AS5600 or MT6701) inside. SA1737 for compact joints, SA1755 for 5.5 Nm.
A 5-axis, 3D-printed robotic arm that knows where every joint is the moment it powers on. Built from standard parts for about €200, programmed with the free Dragon-Arm Programmer app. Gen1 releases on 30 November 2026.
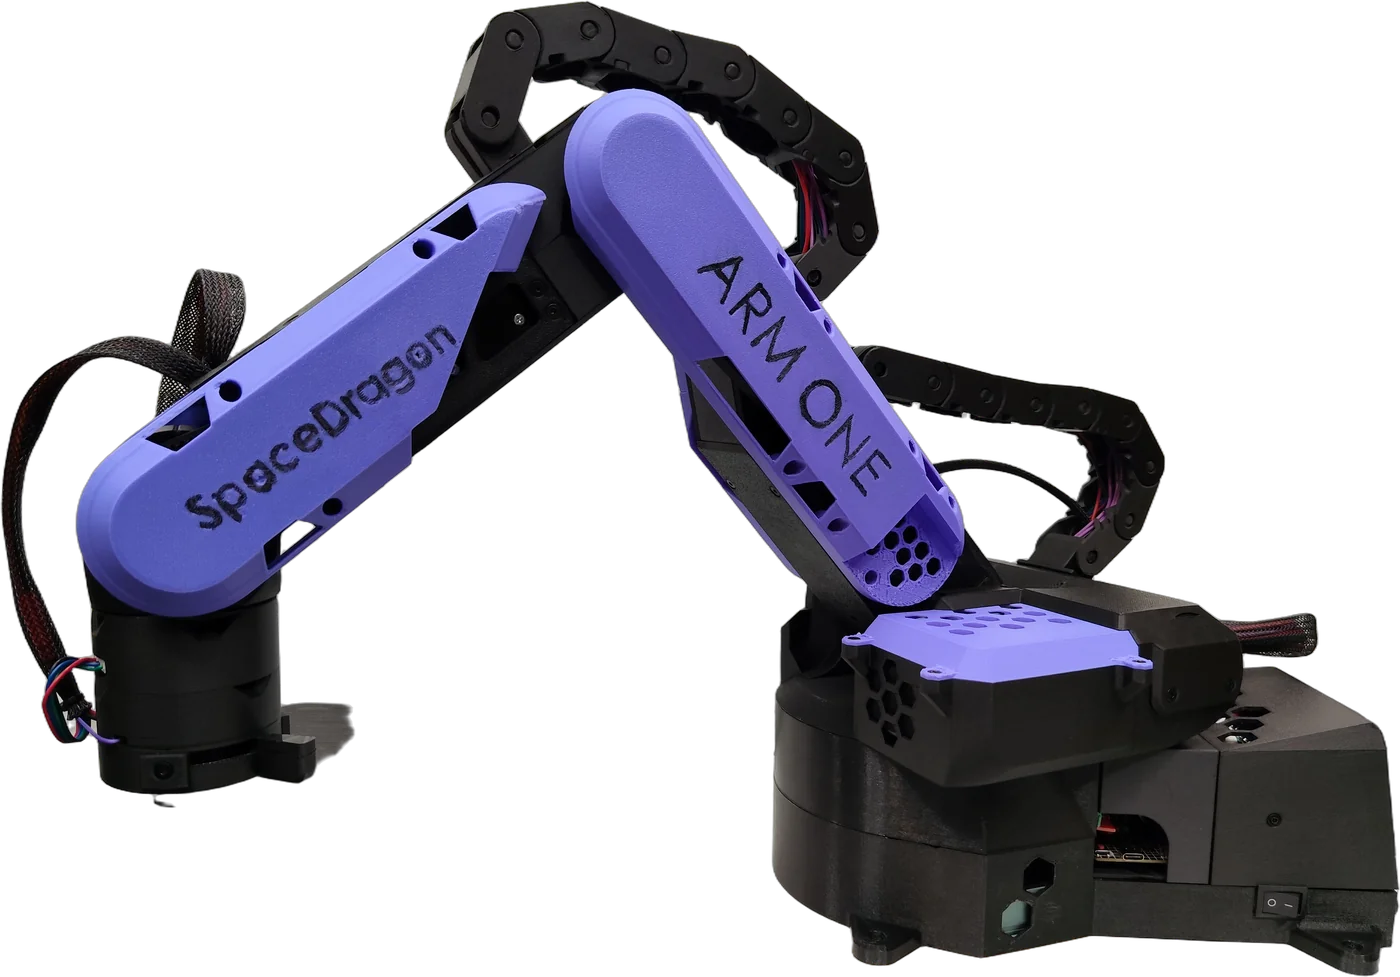
SpaceDragon is an open-source robotics lab. Every project is free to download and comes with drawings, wiring and specs, so you can build it, modify it and actually understand it.
Printable NEMA 17 actuators with a 9:1 gearbox, backlash under 1° and an optional AA360 absolute encoder (AS5600 or MT6701) inside. SA1737 for compact joints, SA1755 for 5.5 Nm.
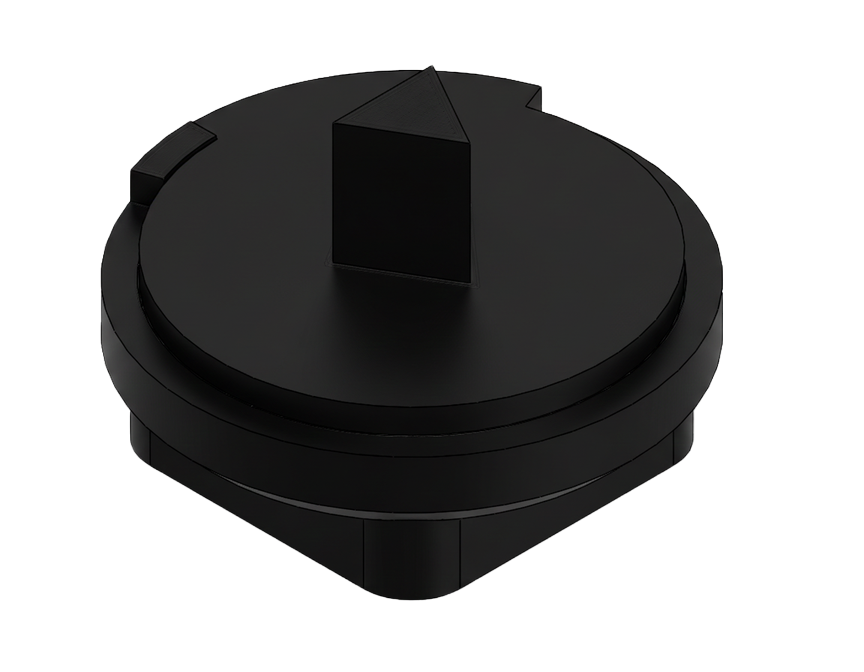
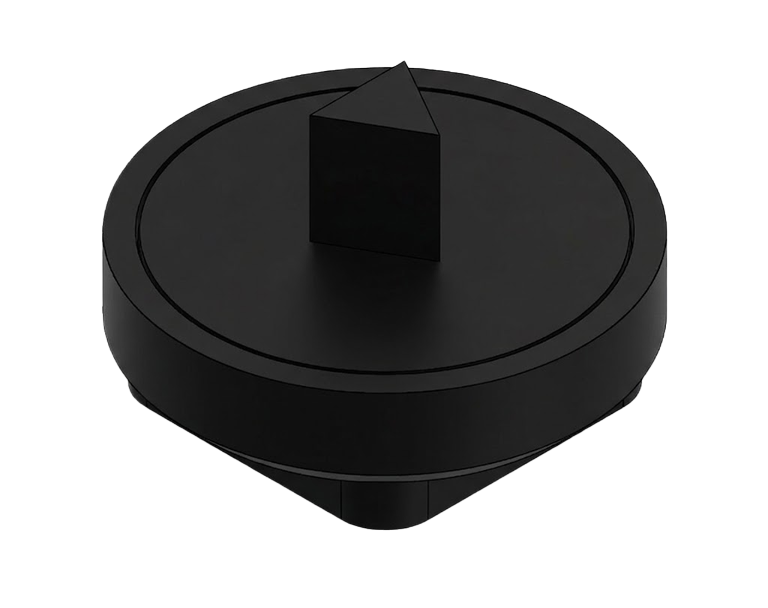
A printable calibrator that turns a cheap AS5600 or MT6701 magnetic encoder board into an AA270 or AA360 absolute angle module: centred magnet, fixed mechanical zero, no re-calibration.
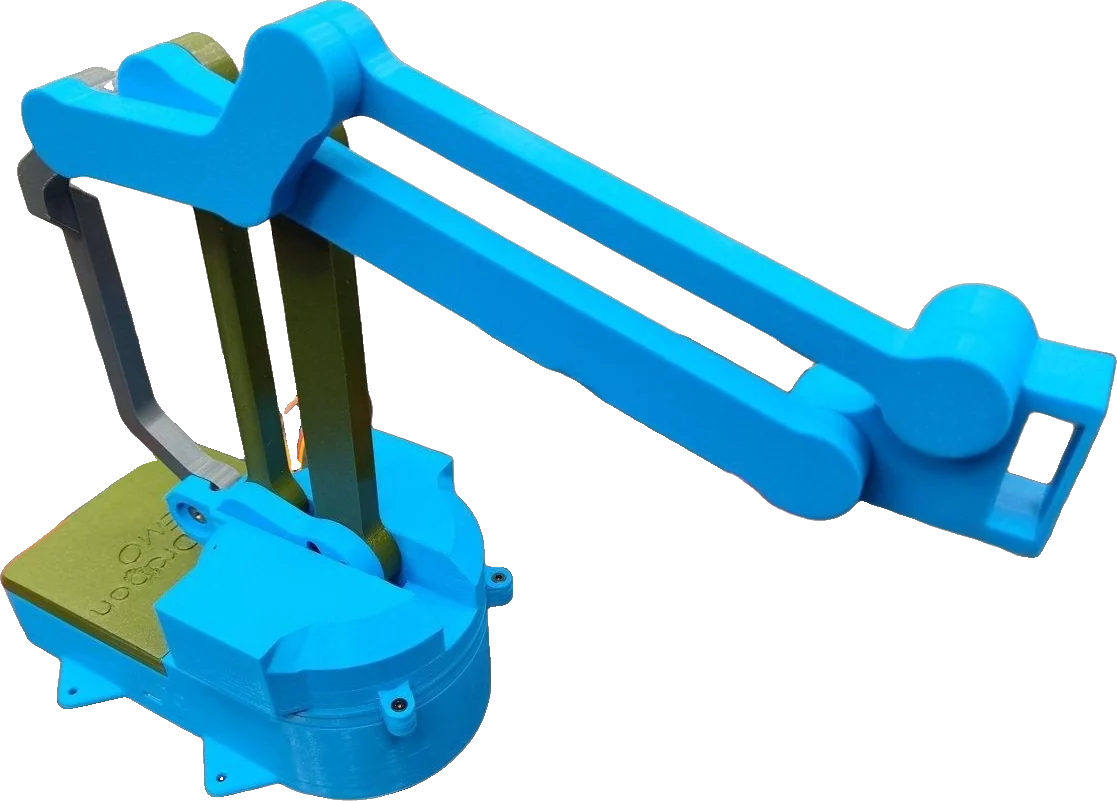
A desktop palletizing arm with a parallel linkage that keeps the tool plate level. Three servos, an Arduino and a PCA9685, programmed visually with the Dragon-Arm Programmer.
Four projects in planning. Numbers are design targets.
Our joints report their true angle from power-up. No limit switches, no zeroing routine after every reboot.
0.022° encoder resolution and gearbox backlash under 1° from printed parts and common electronics.
STEP files, drawings, wiring and documentation, free, so you can modify and repair everything.
Arduino, TMC drivers, PCA9685, MG996R. Parts you can buy anywhere.
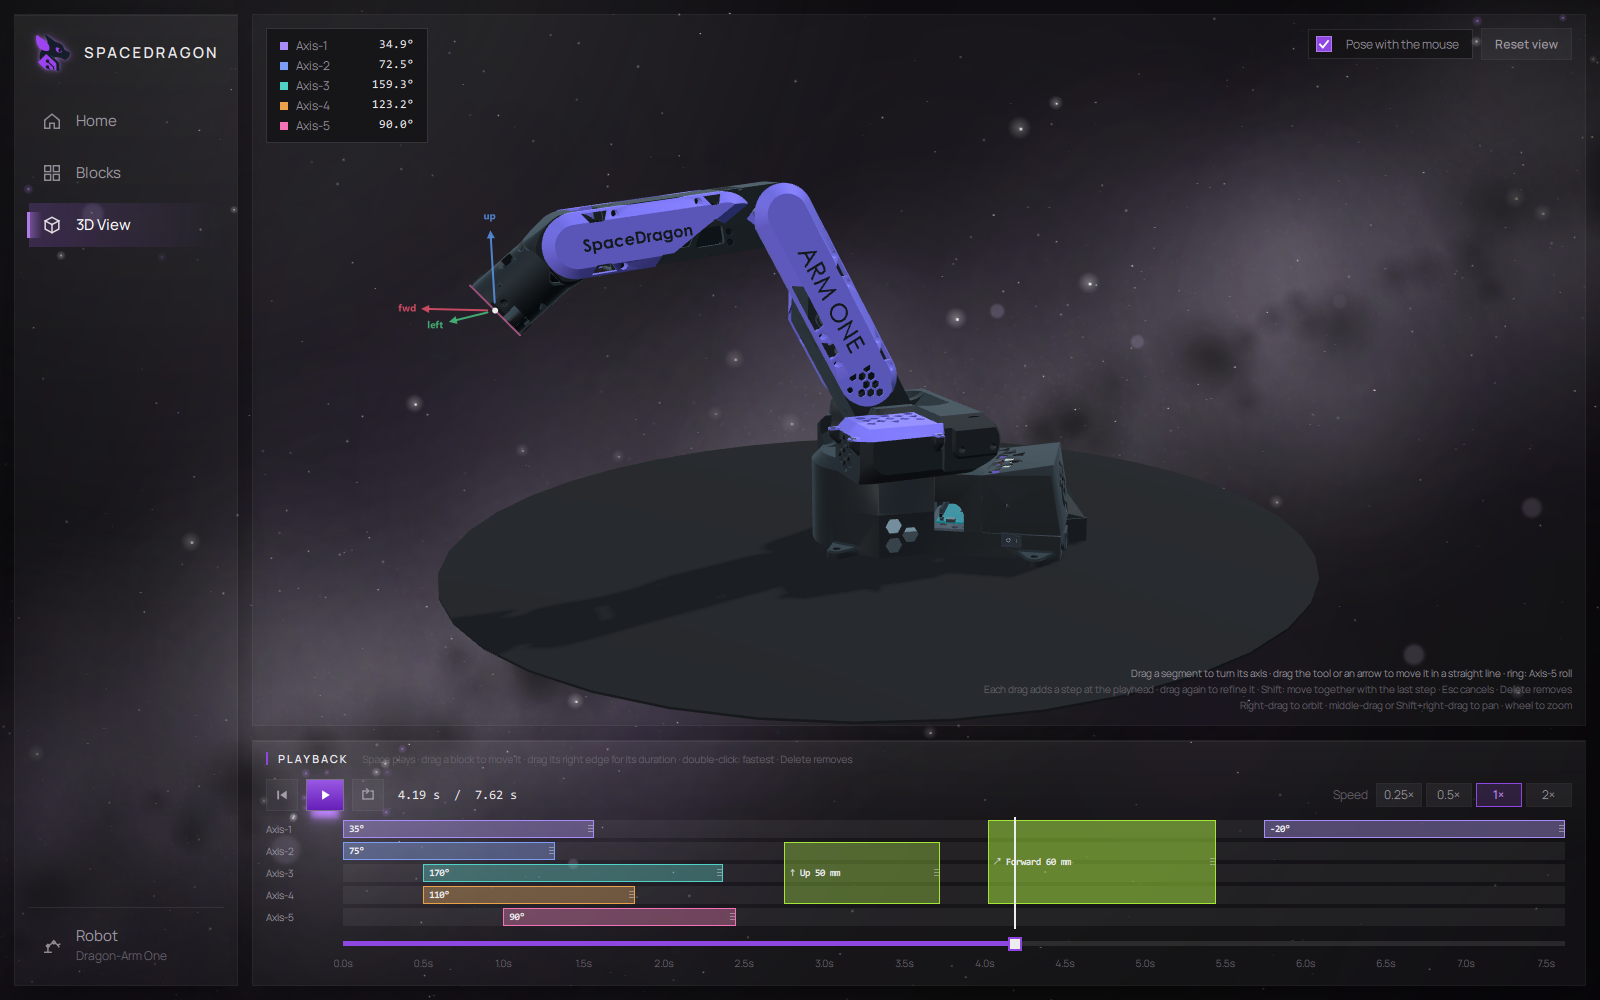
Plan robot-arm motion on a timeline or by posing a 3D model, move the tool in straight lines with inverse kinematics, and export a ready-to-upload Arduino sketch. Fully supports Dragon-Arm One and the Dragon-Arm Demo.
Follow development, ask questions, share your builds and help shape the next projects.